En

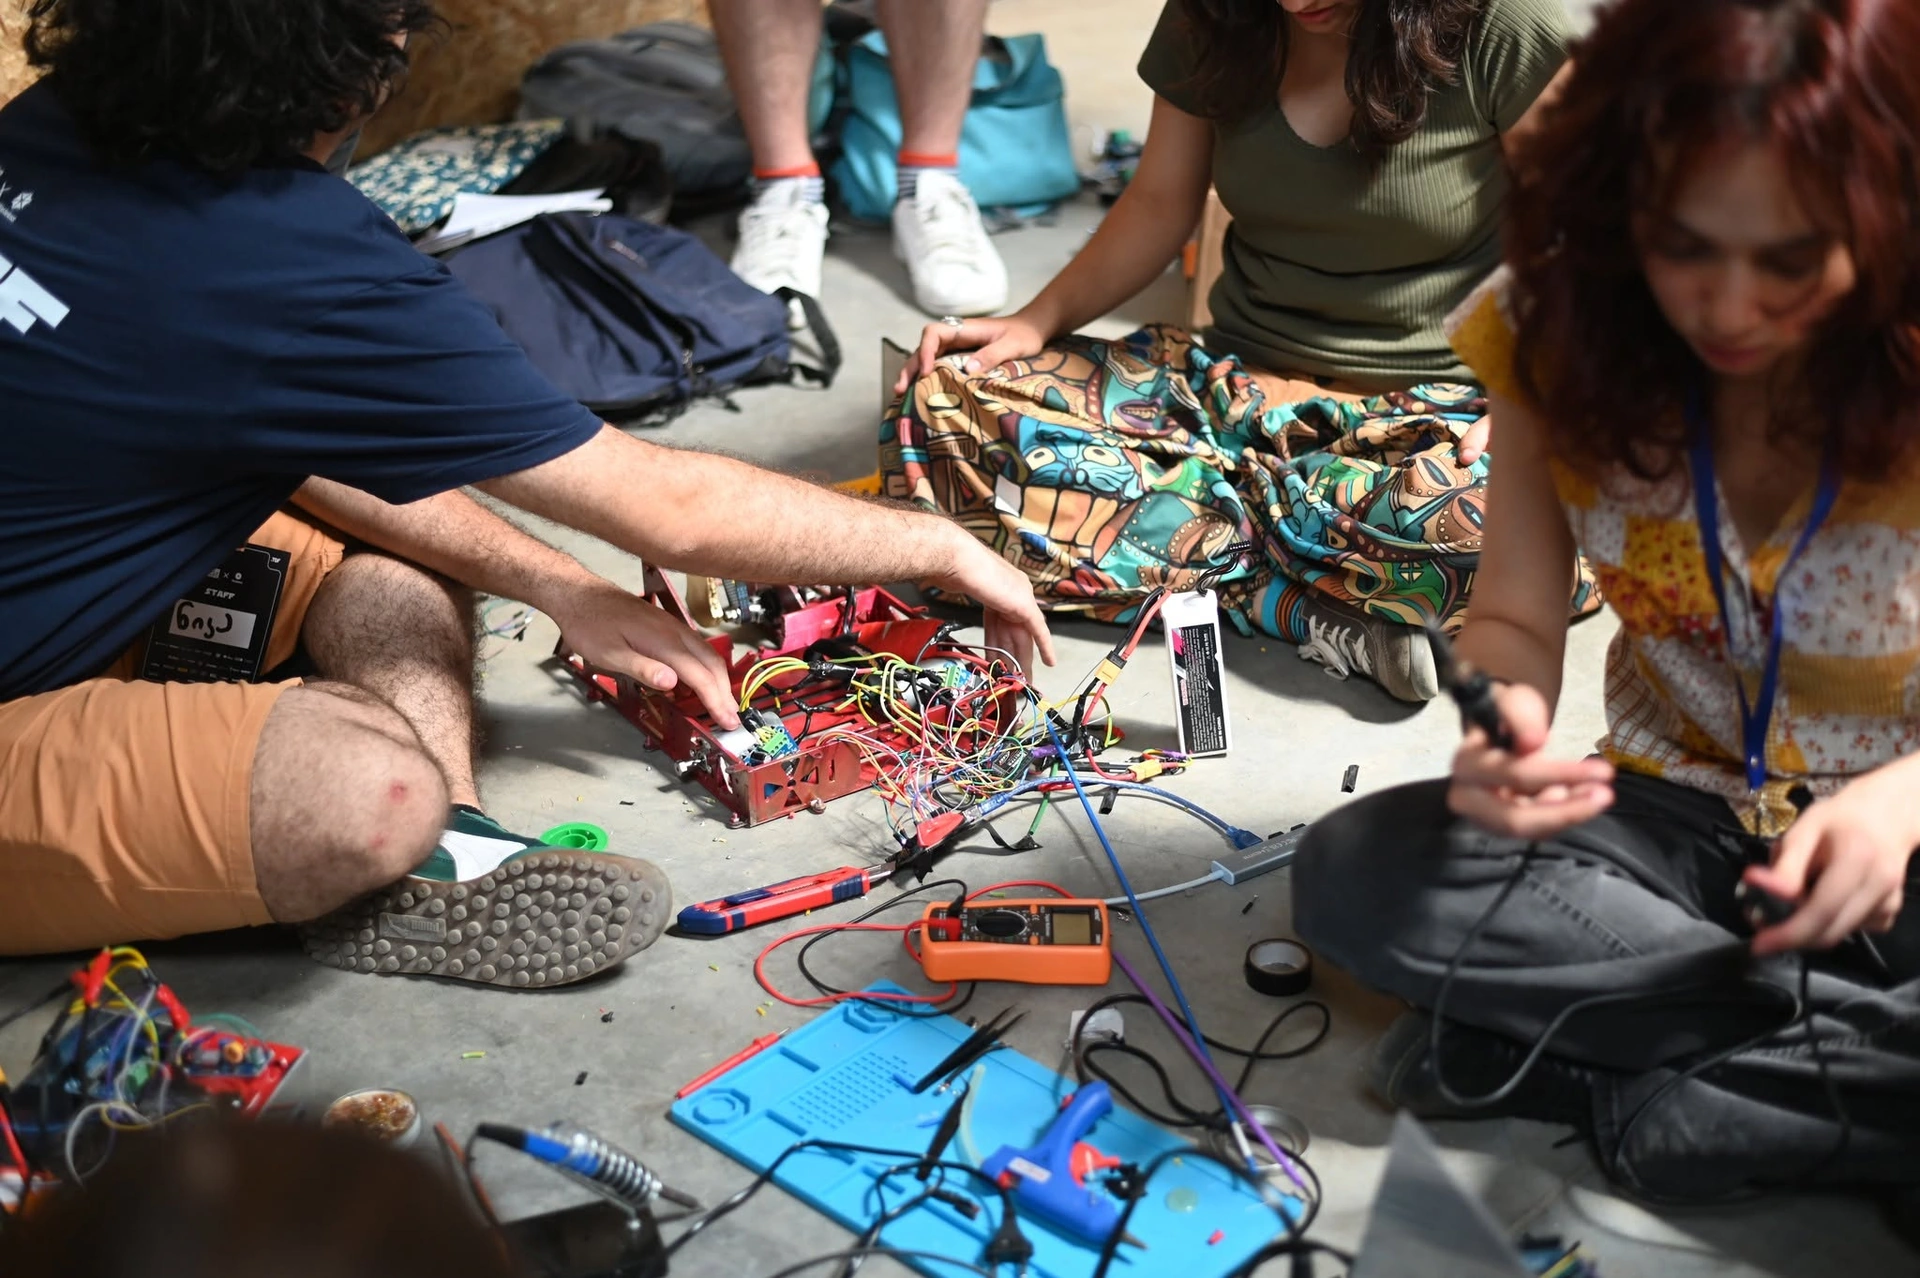
Electronics in robotics: why everything starts here
A robot that "suddenly stopped" almost never has a bug in its code. Far more often a wire has come loose, the battery is flat, a motor drags the voltage down, or two parts don't share a ground (GND). That is why electronics basics come first: once you understand what happens in the wires, half of your problems solve themselves.
This guide goes one step deeper than My first robot. You need no maths beyond multiplying and dividing. Looking for an electronics course? Make this page its first chapter.
Voltage, current, resistance and Ohm's law
Think of water in a pipe:
- Voltage (V, volts) is the pressure: an AA cell gives 1.5 V, USB 5 V, a 2S LiPo battery 7.4 V.
- Current (I, amperes) is the flow: an LED needs 10–20 mA (milliamps), a small gear motor 100–500 mA, and far more when it stalls.
- Resistance (R, ohms, Ω) is how narrow the pipe is.
Ohm's law links them: V = I × R. In the first diagram:
- the triangle: cover the value you want — V = I × R, I = V ÷ R, R = V ÷ I;
- power P = V × I, in watts; a part that gets hot is taking too much;
- the source, 5 V (USB or an Arduino's 5V pin);
- the switch;
- the resistor, which limits the current;
- the LED: the long leg is + (the anode); a red LED drops about 2 V;
- the current, from + through the circuit back to −.
The sum: 5 V − 2 V leaves 3 V for the resistor, so for about 14 mA it needs 3 V ÷ 0.014 A ≈ 220 Ω. Without it, the LED takes all the current it can and burns out. GRA's 2026 SUMO rules agree: a home-made start module's status LED gets about 220–330 Ω.
Series and parallel: resistors and batteries
Parts can be joined in two ways. In the second diagram:
- Series — one after another: the same current flows through both, and resistances add: 100 Ω + 100 Ω = 200 Ω.
- Parallel — side by side: both get the same voltage, the current splits, and two equal resistors give half: 50 Ω.
- Cells in series add their voltage: two 3.7 V lithium cells make 7.4 V — the "2S" on a LiPo pack. The capacity (mAh) stays the same.
- Cells in parallel keep the voltage and add capacity: 2000 mAh. Join only identical cells at the same charge.
A useful series circuit is the voltage divider: Vout = Vin × R2 ÷ (R1 + R2). Two 10 kΩ resistors turn a full 2S battery's 8.4 V into 4.2 V — safe for an Arduino's analogue input, so the robot can watch its own battery.
The parts: diodes, capacitors, transistors and regulators
A handful of parts appear in almost every robot:
- Resistor — limits current, divides voltage, holds an input at a known level (a 10 kΩ pull-up).
- Diode — current one way only, dropping about 0.7 V (a Schottky: 0.2–0.4 V). It protects against a battery plugged in backwards, and goes across motors and relay coils, which spike when switched off.
- Capacitor — a small, fast reservoir: 100 nF ceramic next to each chip's power pins against noise, 100–470 µF electrolytic on a motor driver's supply against current spikes. Electrolytics have a polarity: the stripe is −.
- Transistor — a small current switches a big one: an NPN (BC547 or 2N2222 type) with about 1 kΩ on its base lets a pin switch a relay.
- MOSFET — the switch for real current; a "logic-level" N-channel one turns fully on with 5 V on its gate. A motor driver is four switches in an H-bridge.
- Voltage regulator — a steady 5 V or 3.3 V from the battery. A linear one burns the difference: (7.4 V − 5 V) × 0.5 A = 1.2 W of heat; a switching buck converter wastes far less.
A real example: the kill switch in GRA's 2026 SUMO rules, which cuts the motors' power, is made of exactly these parts — relay K1, NPN transistor T1, diode D1 against the coil's spike, series resistor R2, and an optional R1, as the ready-made module has 1 kΩ built in. See How to build a SUMO robot.
Reading a datasheet and using a multimeter
Every part has a datasheet, the maker's PDF. Read only what you need:
- Absolute maximum ratings — limits, not targets;
- Recommended operating conditions — a 2.7–5.5 V supply, for example;
- Electrical characteristics — typical and worst-case values, such as an LED's forward voltage;
- The pinout — which leg is which;
- The application circuit — the extra parts the maker recommends.
GRA's rules show why the last one matters: for a home-made SUMO start module they point to the 38 kHz IR receiver's datasheet for its extra parts — usually one resistor (about 100 Ω) and one capacitor (about 10 µF).
The multimeter is the most useful tool you will buy:
- DC volts (V⎓) — probes across the part, power on; measure the battery before every test.
- Resistance (Ω) and continuity (the beep) — power off only; the beep finds broken wires and solder bridges.
- Current (A) — the meter goes in series, often with the red probe in another socket. Never touch a battery's terminals in current mode — that is a short circuit — and move the probe back afterwards.
Batteries for robots: voltage, capacity and safety
Choose a battery by three numbers:
- Voltage — cell type × cells in series: alkaline AA 1.5 V, NiMH 1.2 V, lithium-ion (18650) and LiPo 3.7 V nominal, 4.2 V full.
- Capacity (mAh) — 1000 mAh gives 1 A for about an hour.
- Maximum current — on a LiPo, the C rating: 1000 mAh at 20C gives 20 A, enough for motors that stall or push.
In practice: AA cells for a first, slow robot (not a 9 V battery — it cannot feed motors); two 18650 cells with a protection board (2S) for line followers; a LiPo for the most current per gram — fast and fighting robots — with the most care.
LiPo safety: a balance charger only, never unattended, in a fire-safe bag; never below about 3.3 V per cell; never puncture, bend or short it; retire a swollen pack. A fuse near the battery is cheaper than a burnt driver.
Check the battery the day before an event: GRA's 2026 SUMO rules want it sufficiently charged by check-in. The same rules allow any electronics, home-made included, as long as it meets safety standards.
First circuits on a breadboard, and soldering safely
A breadboard lets you build without soldering. In the third diagram:
- the power rails — each row connected end to end; red is +, black is − (GND);
- a strip of five holes, connected inside;
- the centre channel between the halves — a chip or a button straddles it;
- a push button across the channel;
- a 220 Ω resistor (red, red, brown);
- the LED, long leg on the resistor's side;
- a jumper wire to the − rail.
Press the button: the LED lights. Next: measure the voltage on each part; watch a potentiometer's middle leg go from 0 to 5 V; switch a small motor with a transistor or MOSFET (a diode across the motor); dim the LED with Arduino PWM — see Arduino for beginners.
When a circuit works, solder it: breadboard contacts loosen, and a robot is all vibration.
Soldering safety: the tip is 300–350 °C — always put the iron back in its stand. Ventilate the room: flux smoke irritates the airways. Wear safety glasses when cutting leads; wash your hands after leaded solder. Cool a burn under running water for 20 minutes. Never solder with the battery connected, and never work on mains (220 V) — use a ready-made power supply.
What next: from electronics to a robot
- Put the parts into a robot: the two-wheel project is in My first robot, the programs in Arduino for beginners.
- See the same parts in a line follower, a SUMO robot and a combat robot's wiring; look up terms in the robotics glossary; teachers, see starting a robotics club at school.
- Show your work: schools presented robots and electronics projects at GRA's STEAM project competition 2026, and the Robo Festival 2024 winners received sets of electronic components.
Find the next event on the competitions page — each championship publishes its current rules on its own page — and more articles under the Electronics tag.